AJ Santa Cruz
Selected work
17 projects · 2023–2026Mechanical Confidential
Precision-Motion Digital Twin
Static, modal and harmonic FEA of a precision-motion platform, where a 100 GB solve that failed now converges in 34 seconds.
 P·02
Mechanical / Electrical Active
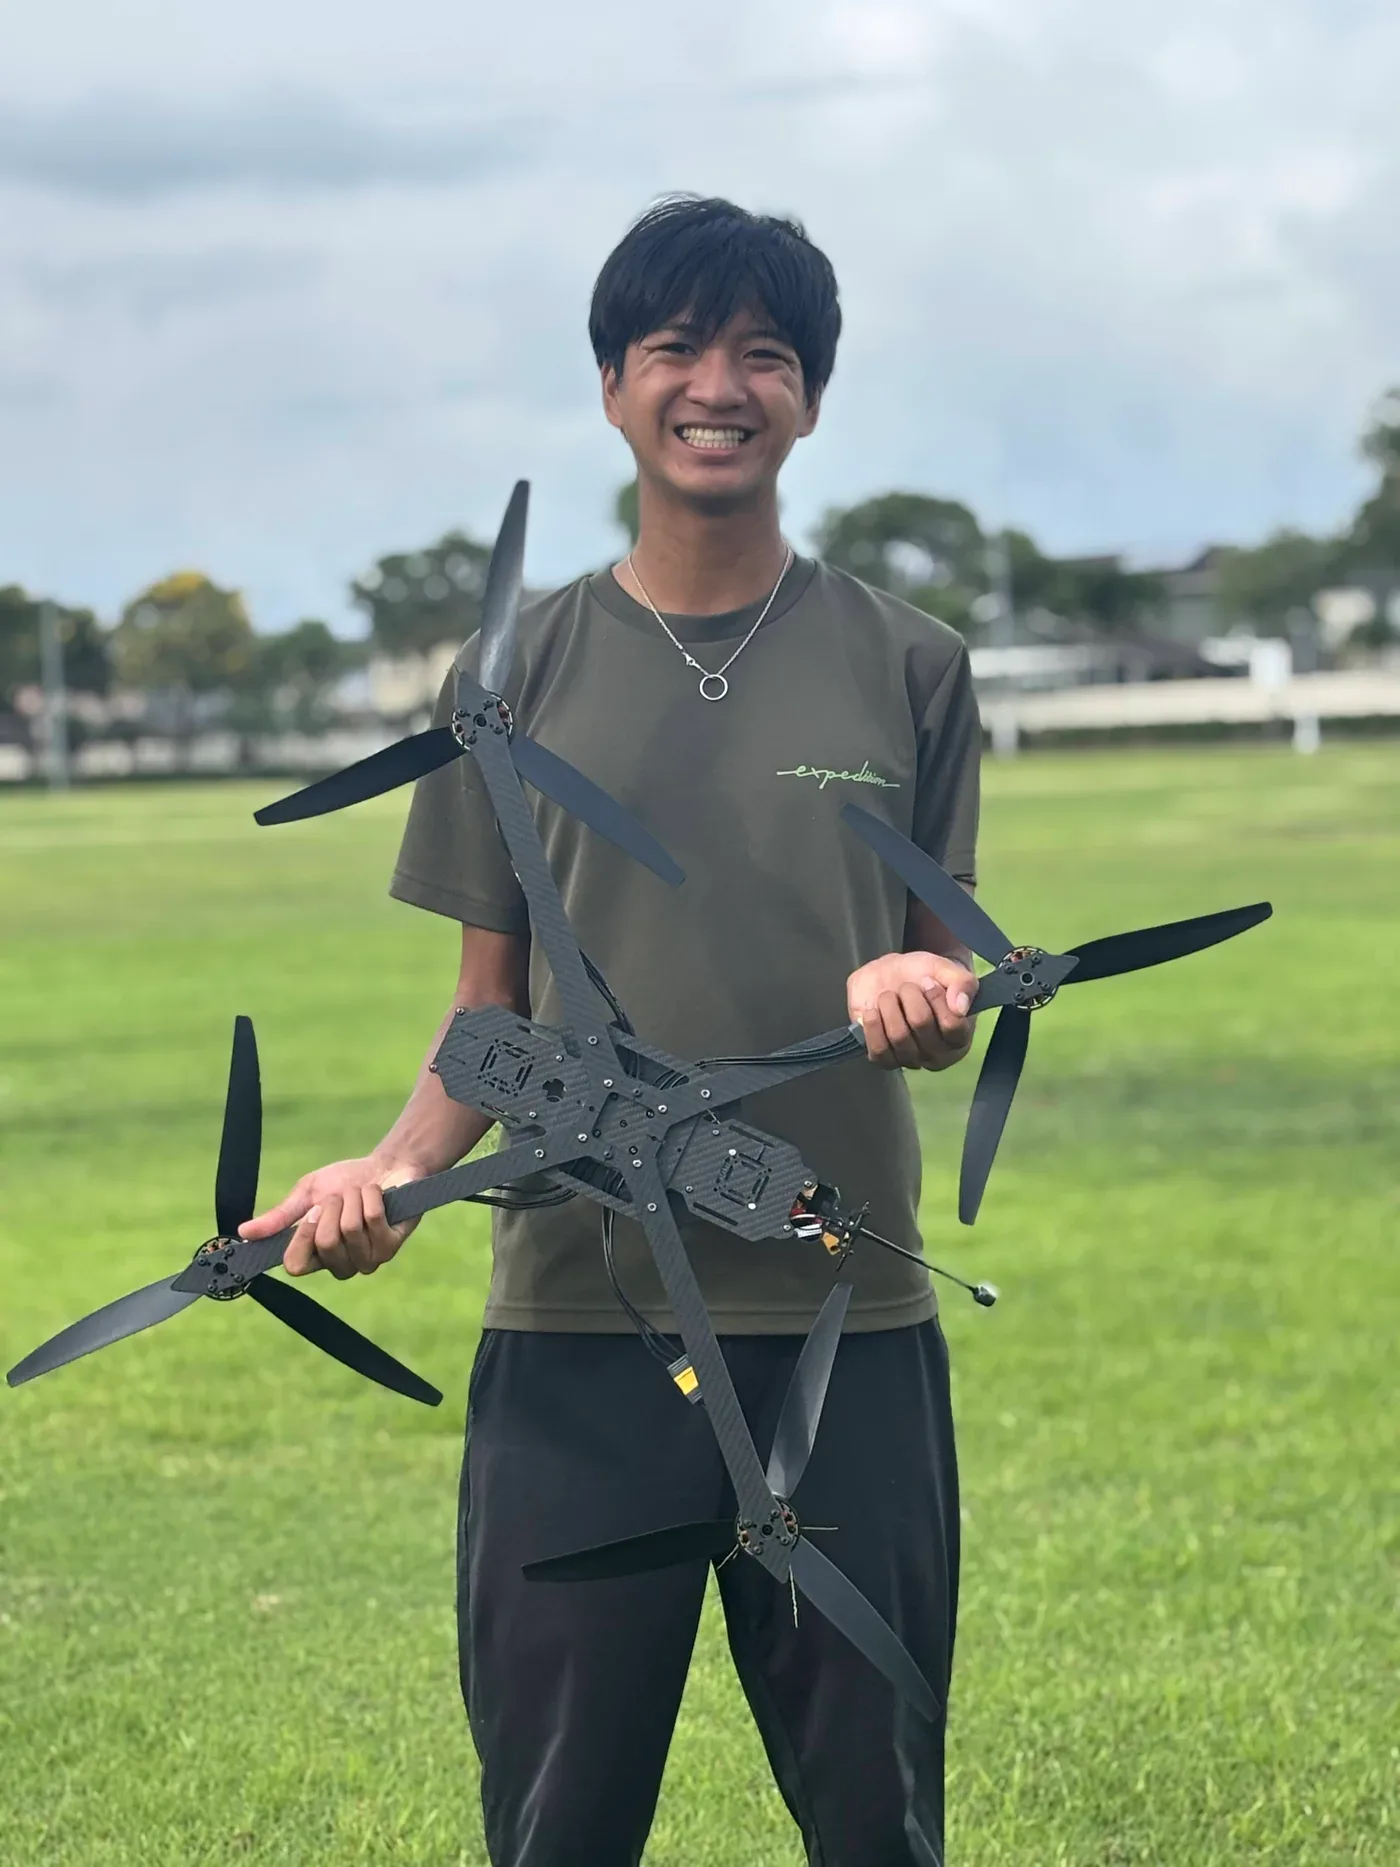
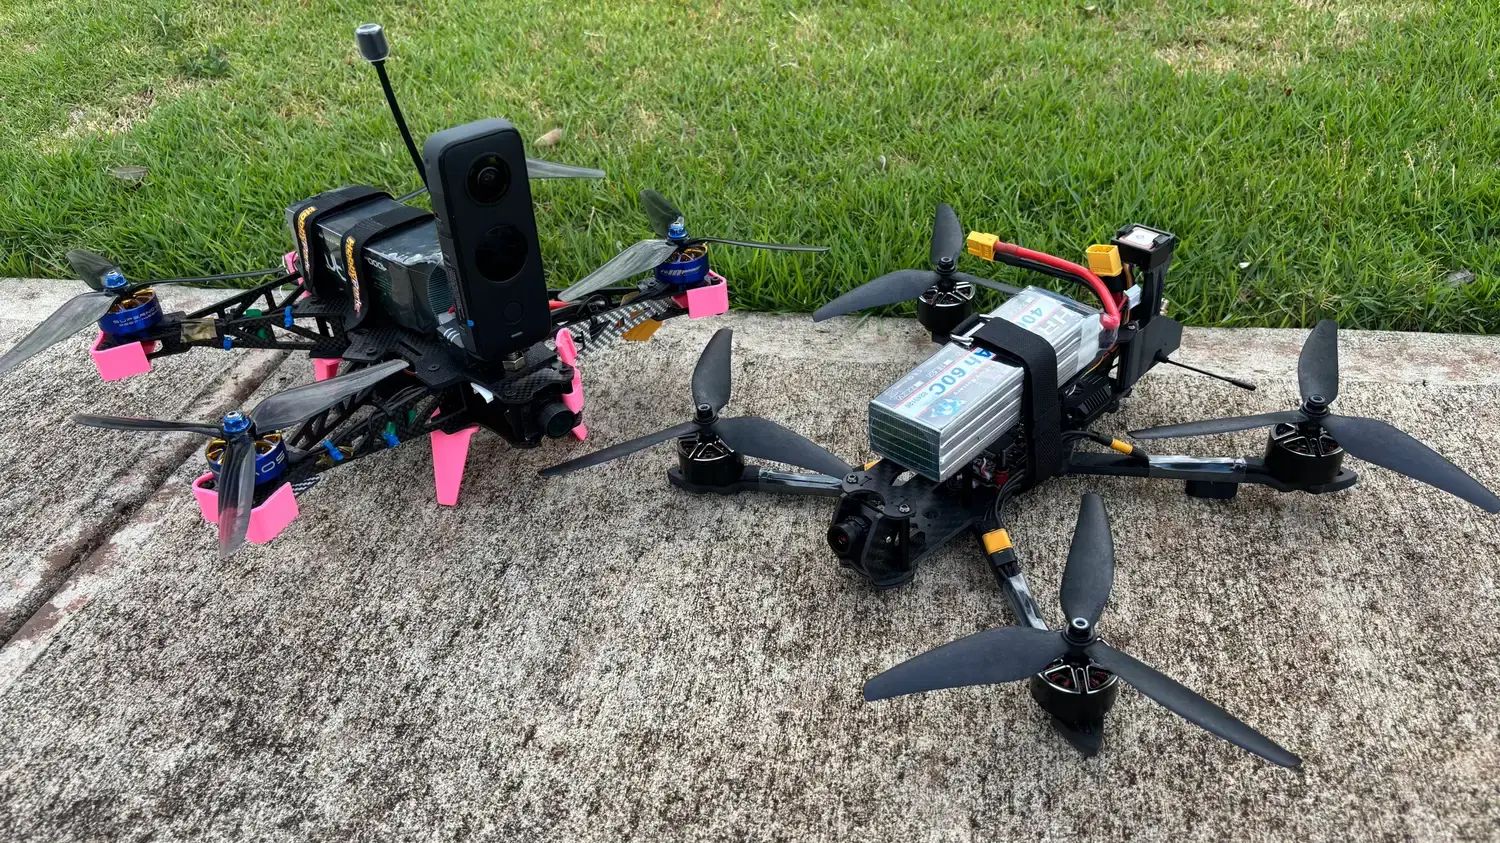
360° Survey Drone for Crack Detection
An autonomous survey drone on an open ArduPilot stack, with its camera mounts and filtering reworked to stop vibration smearing the 360° footage.
Mechanical / Electrical Confidential
Autonomous Tissue-Targeting Insertion Device
A mouse-sized autonomous insertion device with two-piston, 3-DOF actuation, designed to confirm a hit from the blood flash instead of a force sensor.
 P·04
Electrical Complete
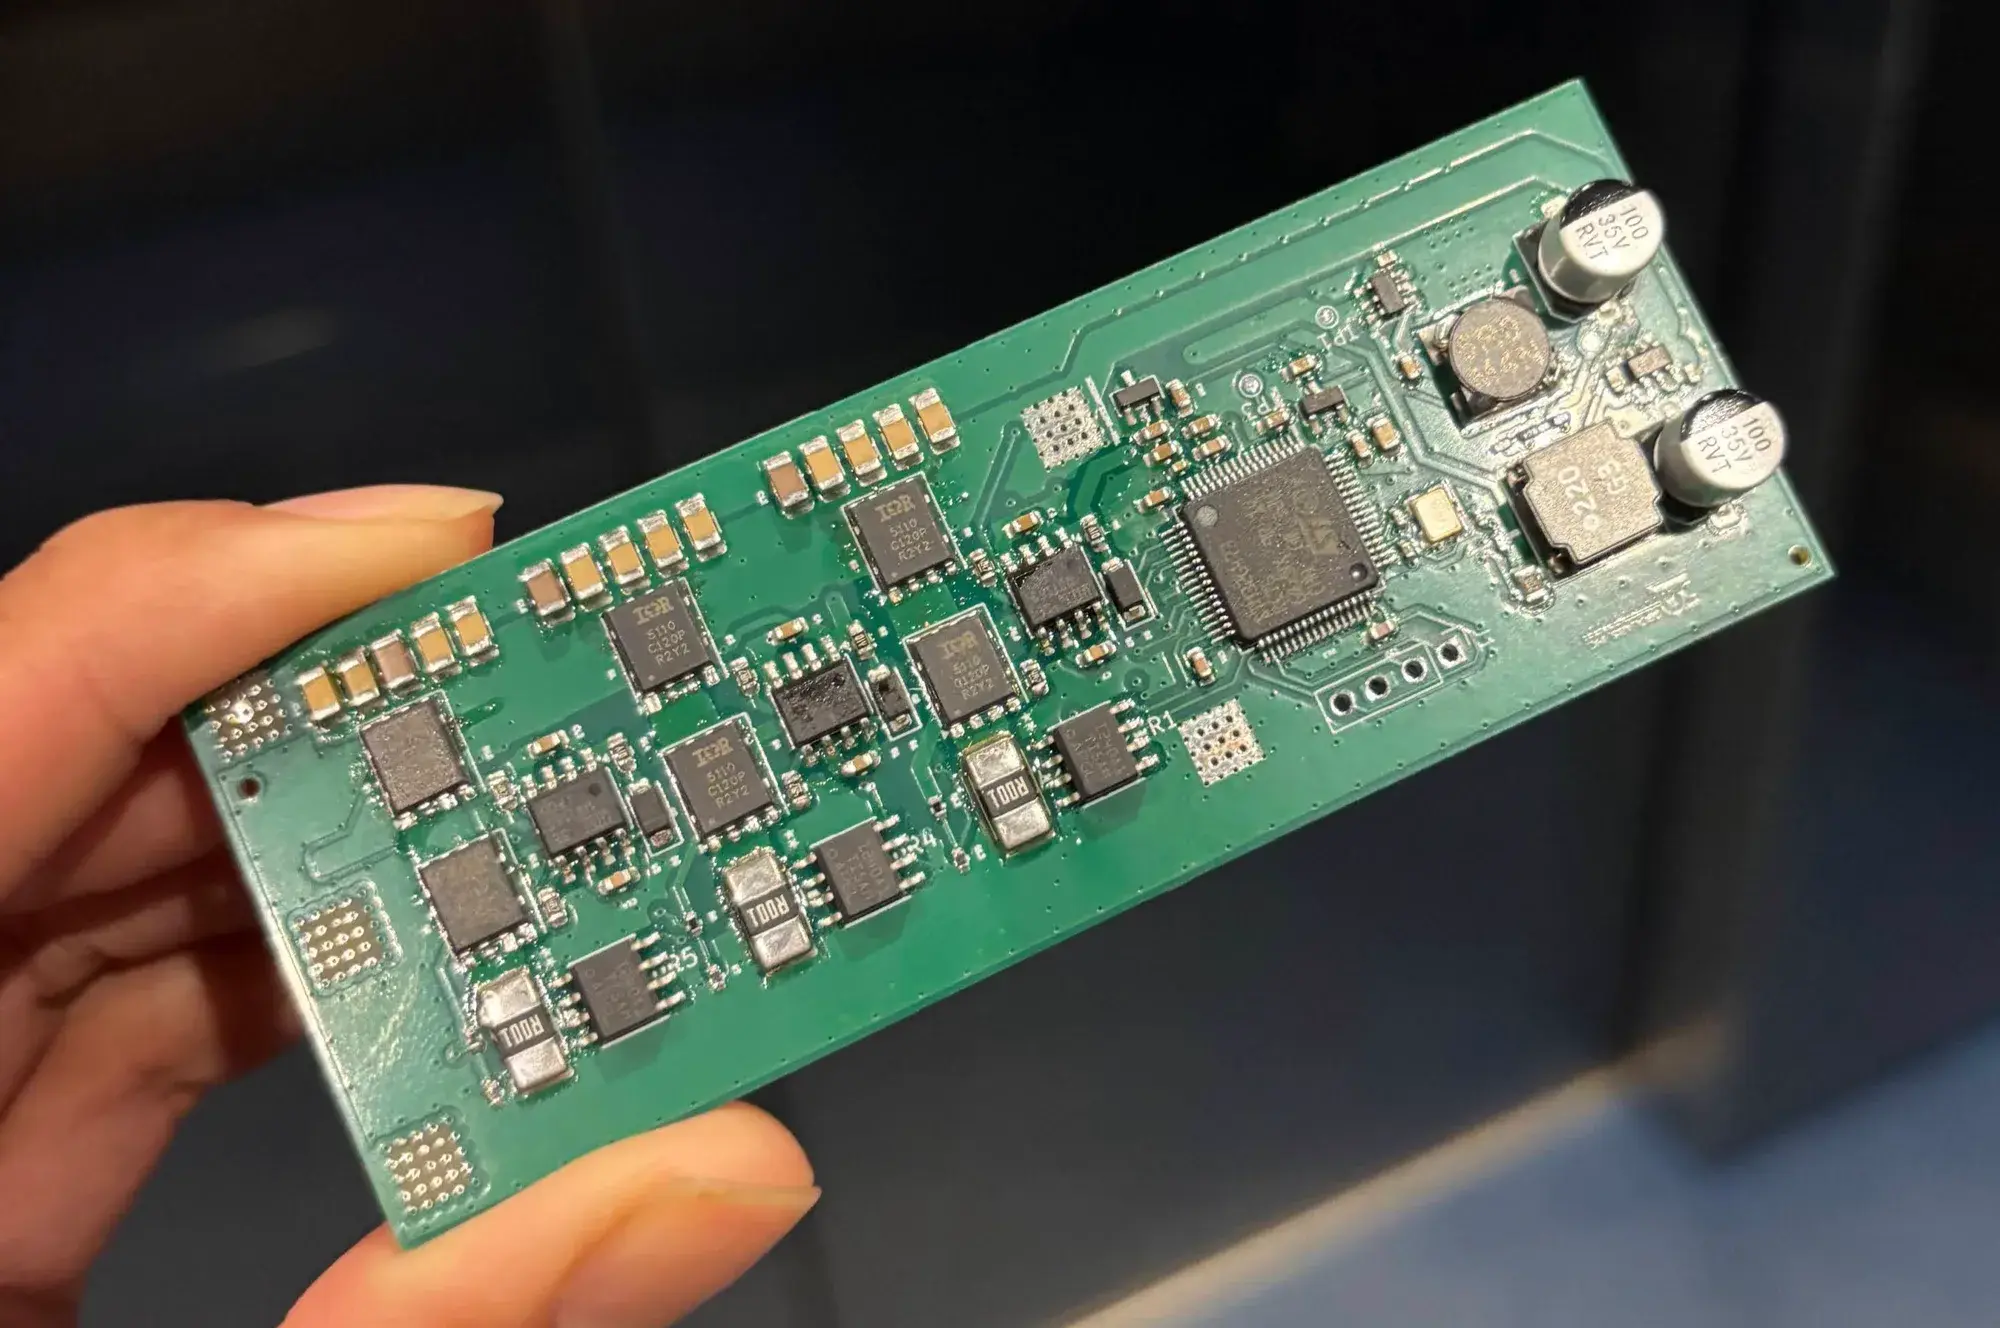
STM32 6S FOC Motor Controller
A four-layer sensorless field-oriented-control (FOC) ESC for a 340 KV drone motor, laid out to keep current sensing clean beside the switching stage.
 P·05
Mechanical / Machine Learning Active
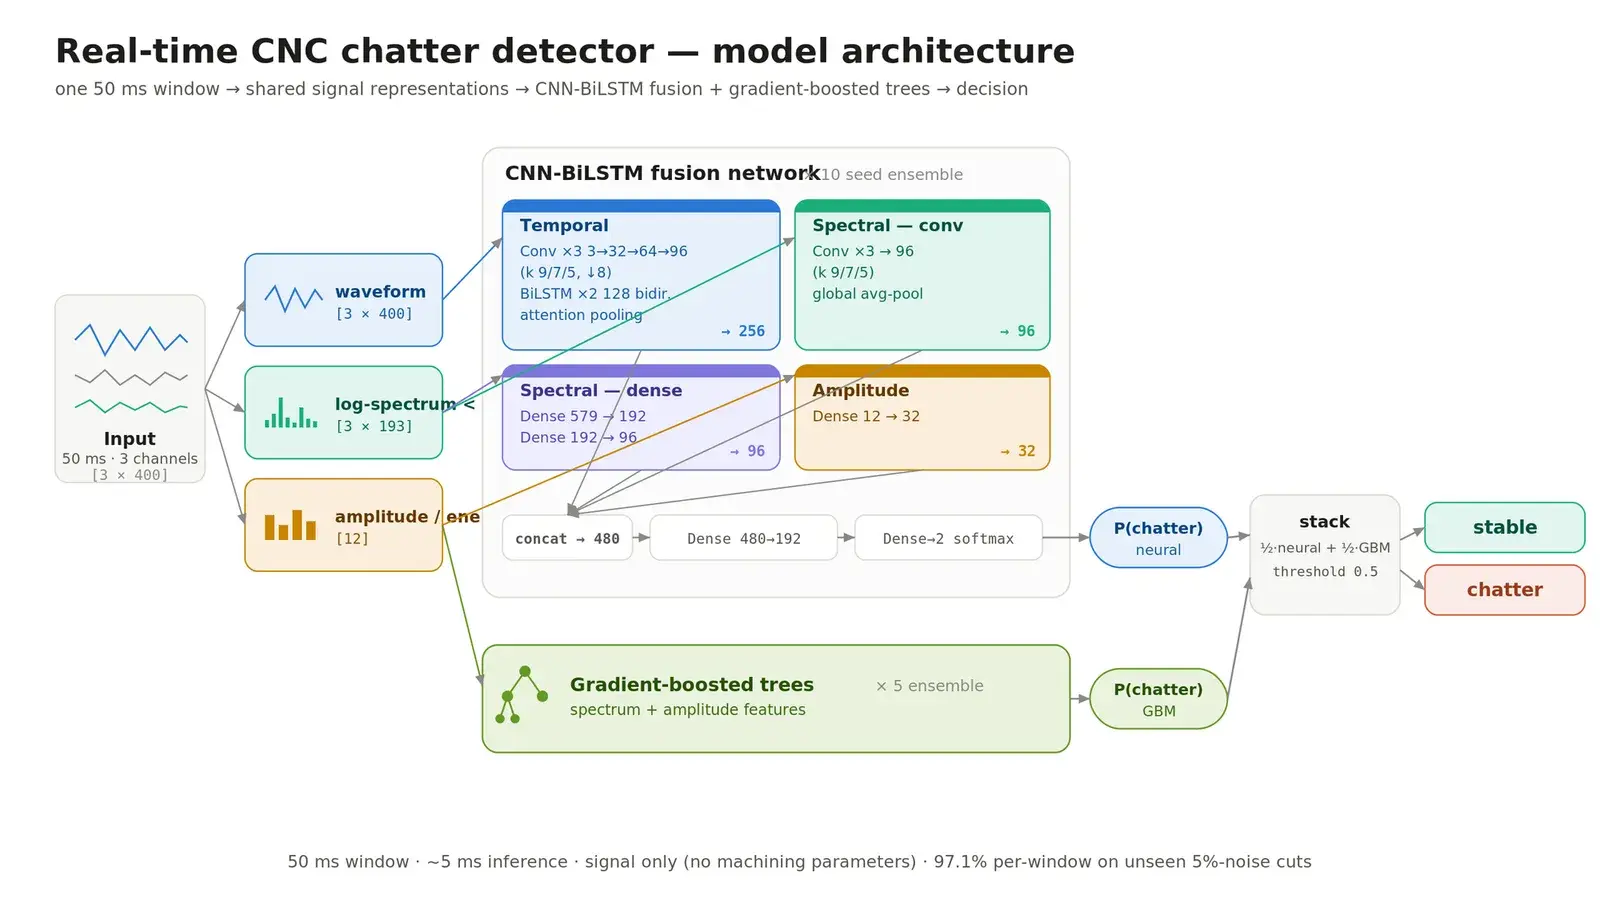
Real-Time Chatter Detection
A signal-only detector that flags milling chatter every 50 ms and stays accurate on noisy cuts after training only on clean ones.
Electrical / Mechanical Confidential
Linear Synchronous Reluctance Motor
A magnet-free linear motor that makes thrust from translator saliency, shaped by topology optimization to more than 4× the force of published designs.
 P·07
Mechanical Active
TechAmp CNC Curriculum
Parts, CNC programs and lab lessons for an MIT hands-on machining curriculum now at six community colleges, with programs rewritten for two mills.
Mechanical Confidential
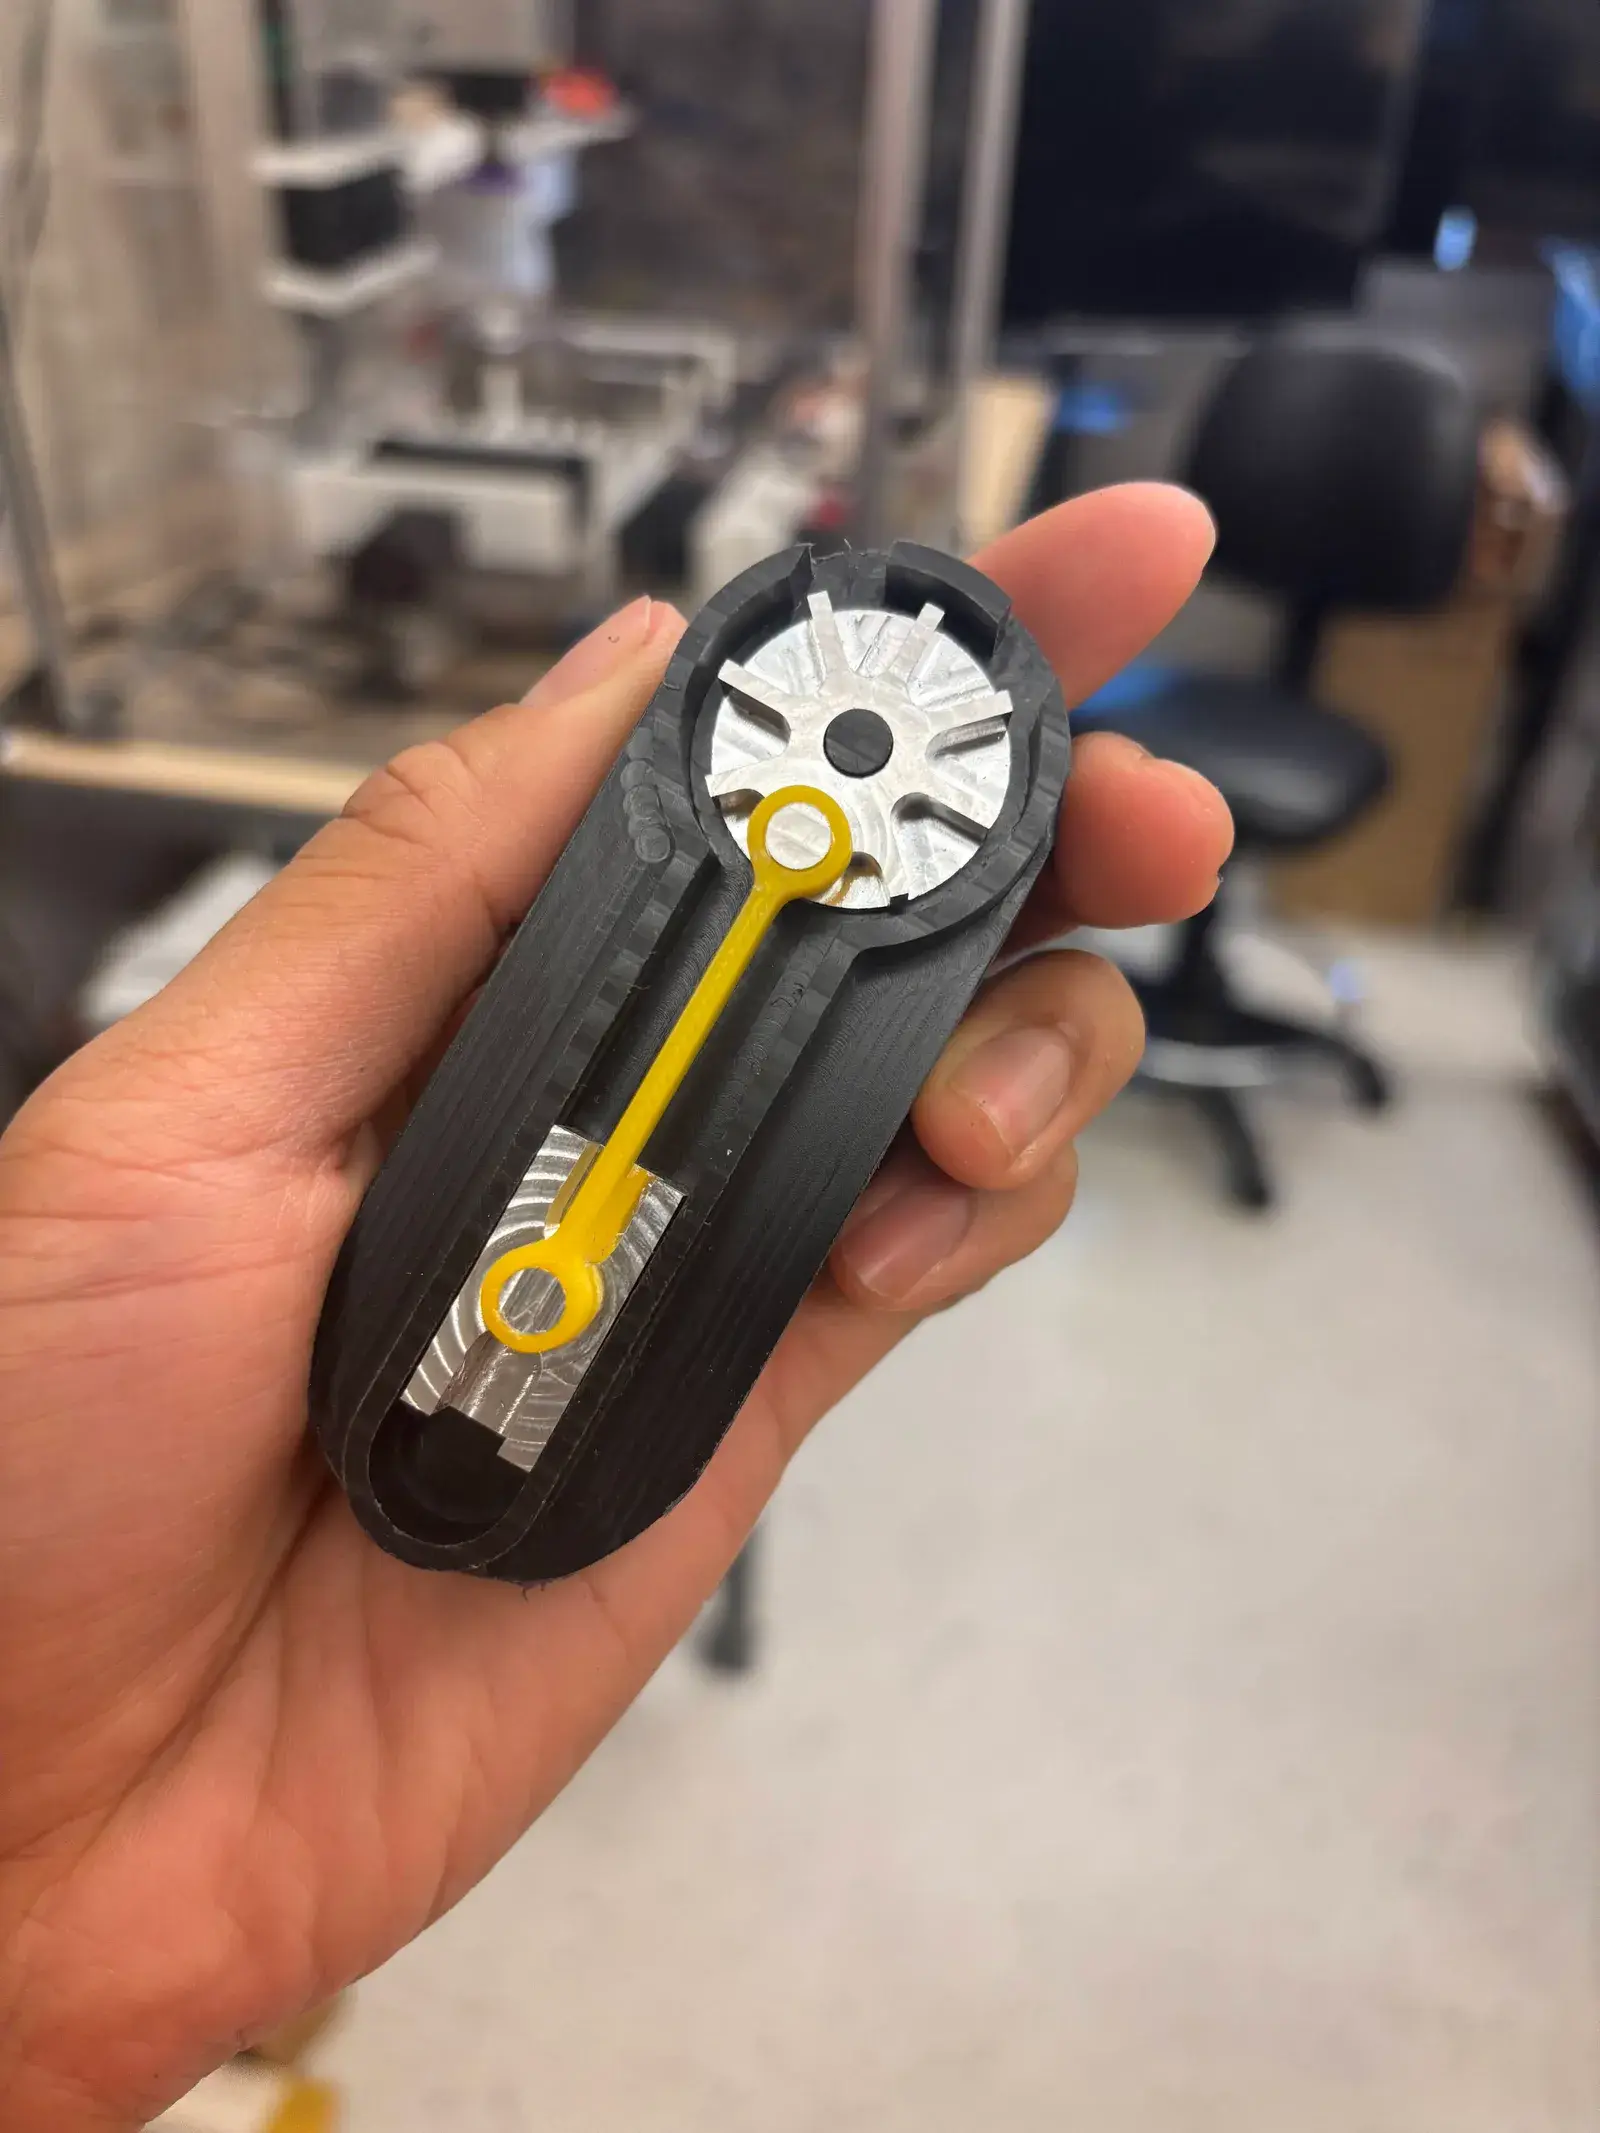
Optical Filter Changer, Redesigned for Manufacturing
The Quantum Nuova filter changer, redesigned around its real accuracy need: from $350 to $15 per unit with a waterjet-cut part and a DC motor.
 P·09
Mechanical Complete
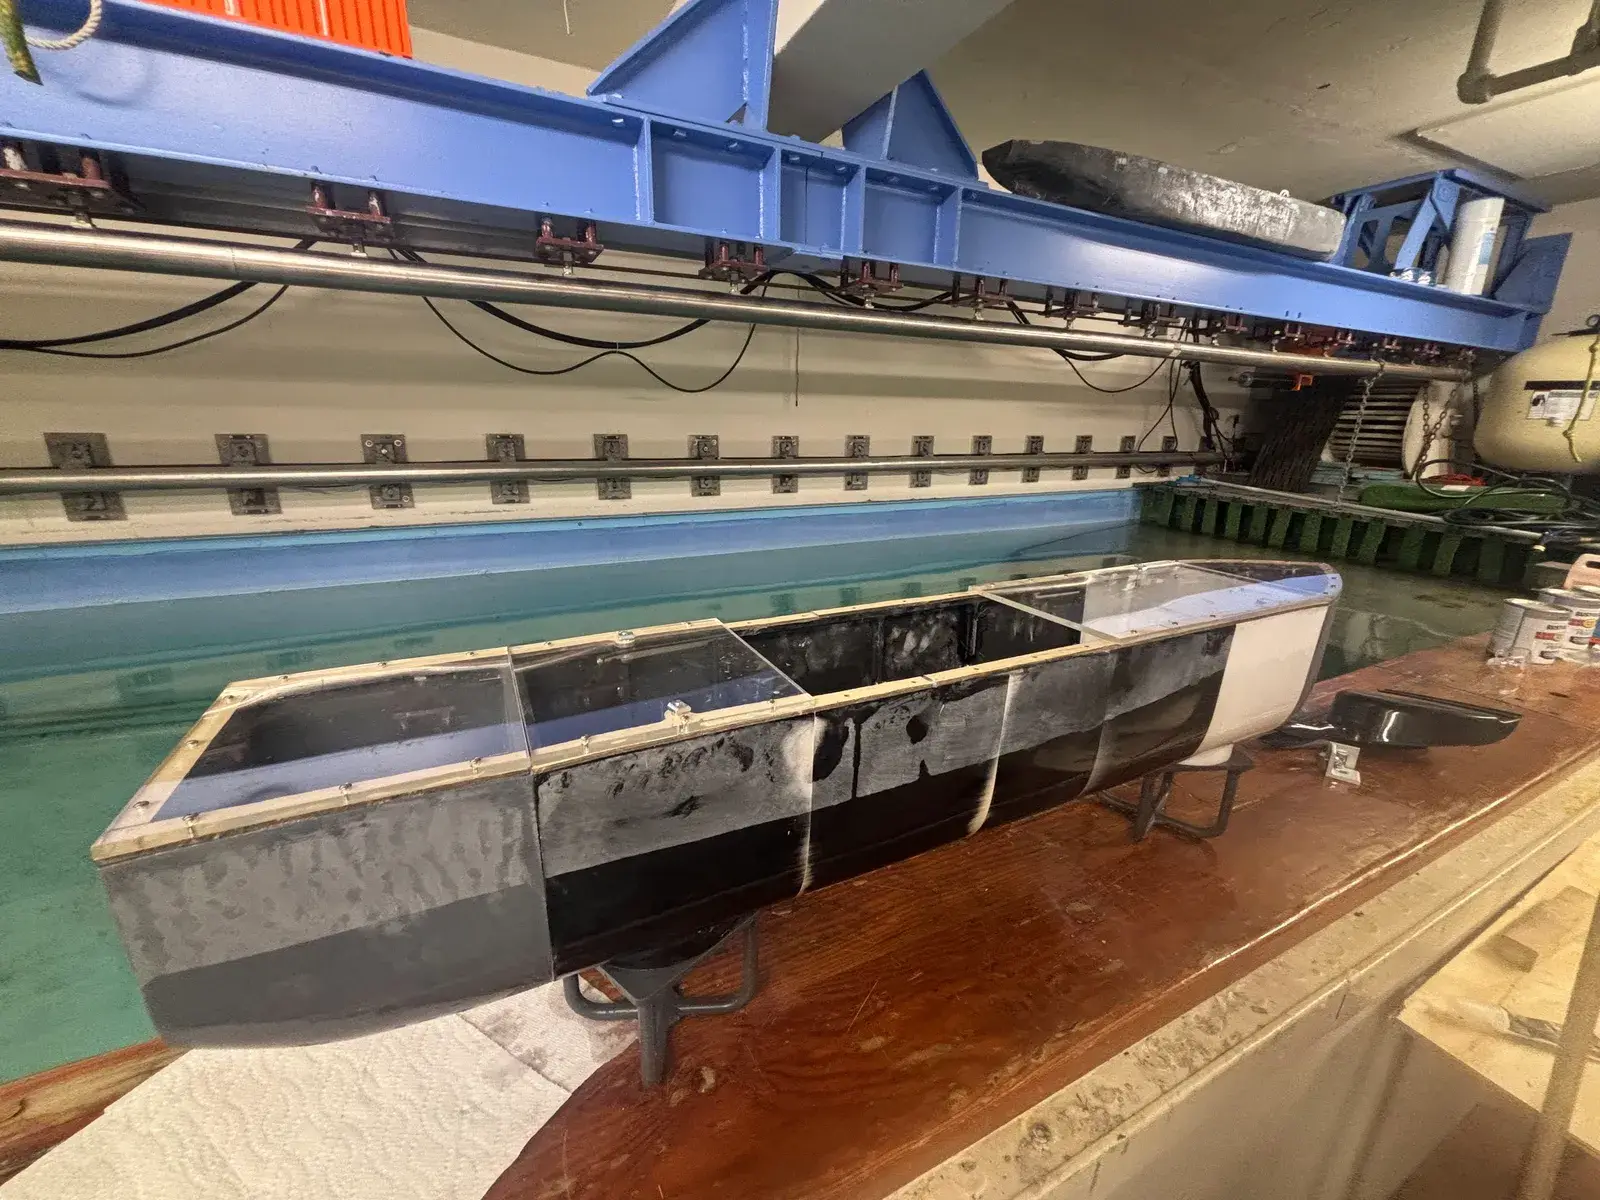
Modular Catamaran Hull: Tow Tank and Multiphase CFD
A modular, instrumented catamaran hull tested to Froude 0.7, and a multiphase CFD model made mesh-independent at up to 75% lower compute cost.
Mechanical / Electrical Confidential
Sub-Microliter Liquid Handling
An automated liquid-handling subsystem for the Quantum Nuova that pairs a peristaltic pump with a PI piezo XY stage at 10 nm sensor resolution.
 P·11
Mechanical Complete
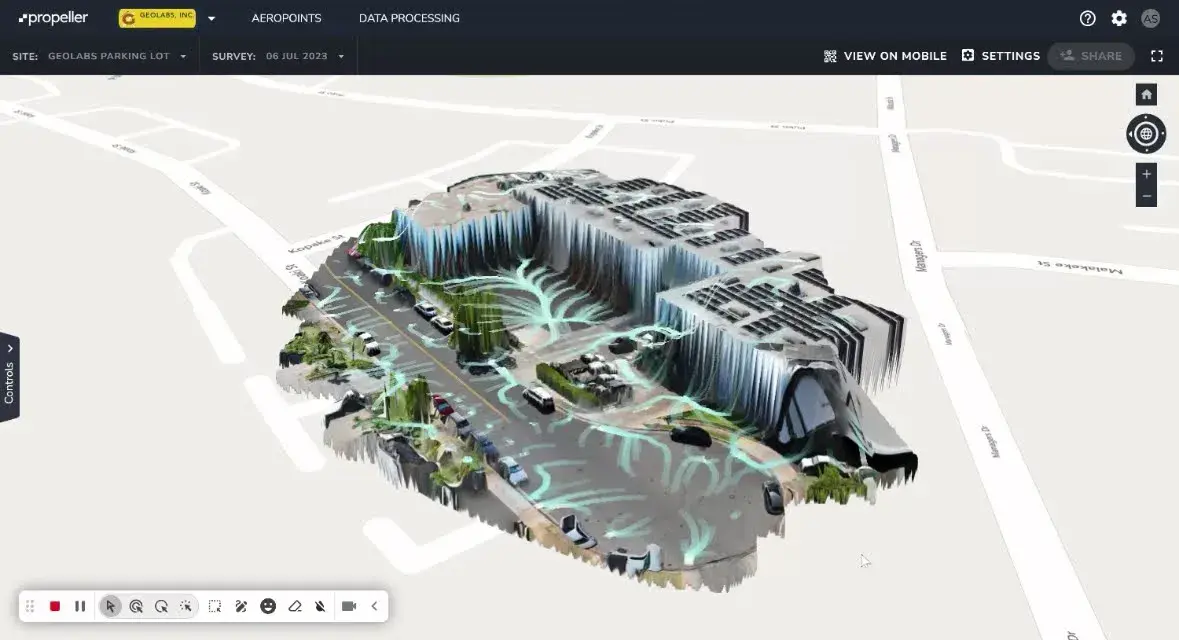
Drone Photogrammetry for Flood and Runoff Modeling
Drone photogrammetry turned into a georeferenced 3D surface for flood modeling, anchored with ground control points for about 10 mm accuracy.
Mechanical Confidential
Instrument Enclosure DFM and a CAD-to-FEA Pipeline
A 500+ lb instrument enclosure moved from thick aluminum to sheet metal with modal FEA, cutting lead time from 8 to 2.5 weeks, plus a CAD-to-FEA prep tool.
 P·13
Mechanical / Electrical / Machine Learning Complete
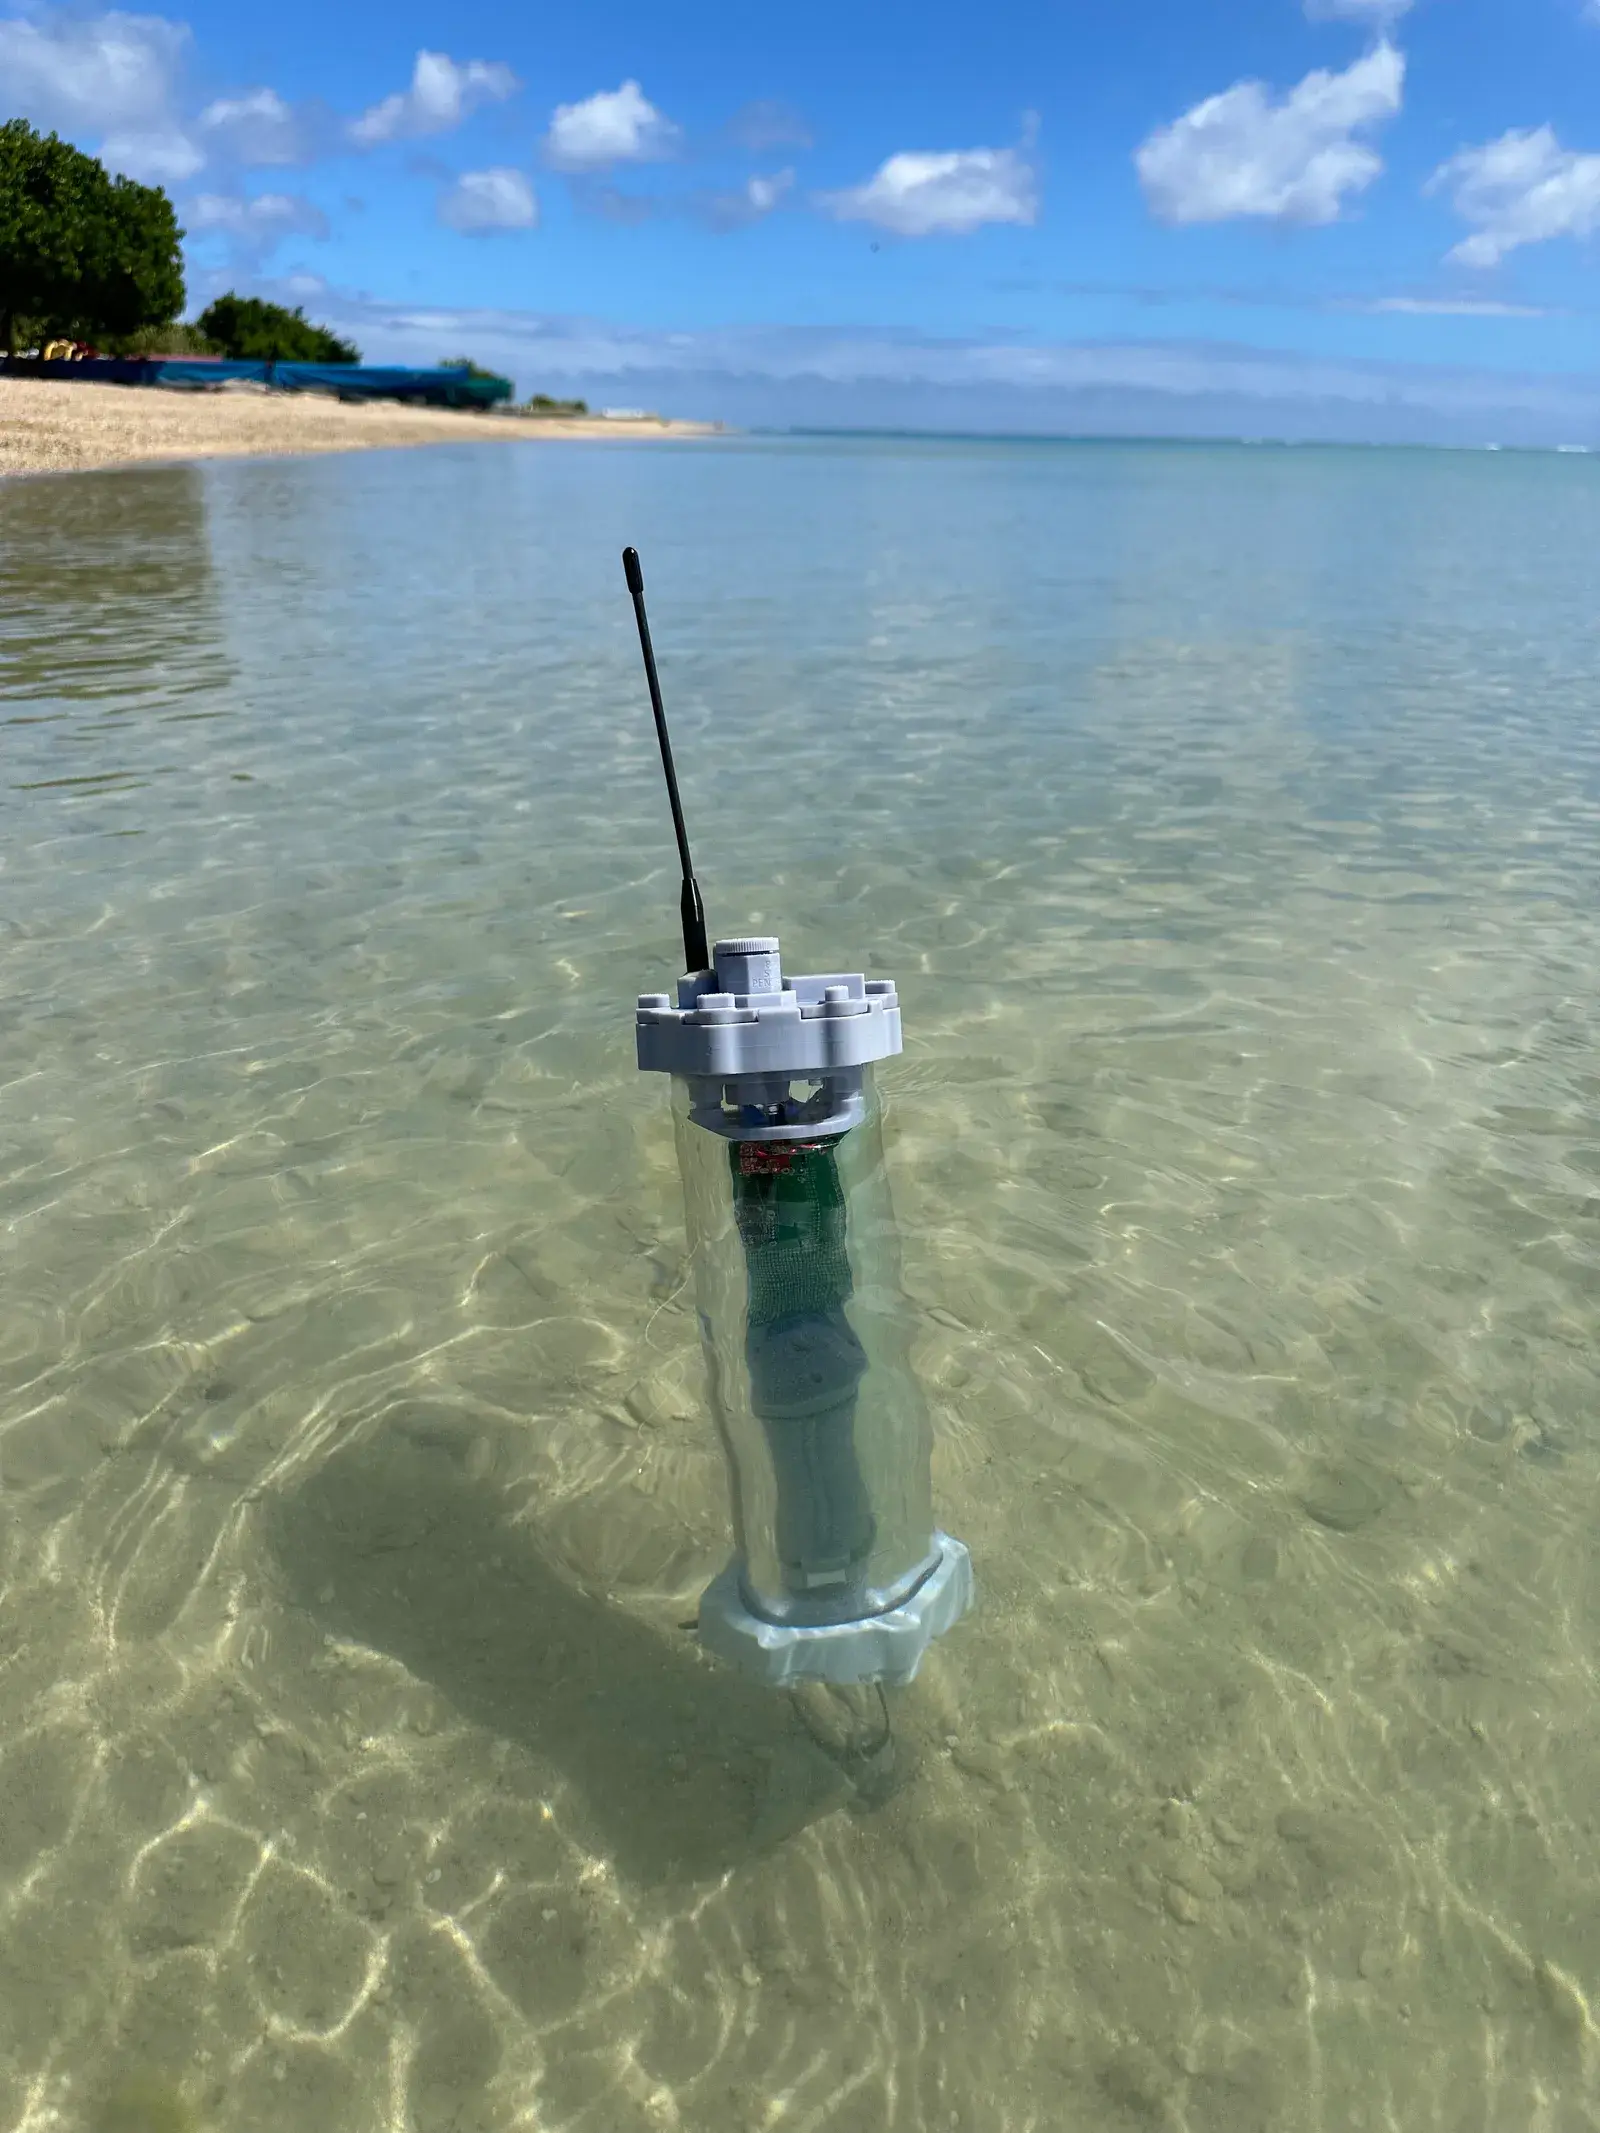
Invasive Algae Detection with MiSo and Neural Networks
Classifying invasive vs native algae from water chemistry with a neural network, on a sealed low-cost sensor platform 99.5% cheaper than commercial options.
 P·14
Mechanical / Electrical In progress
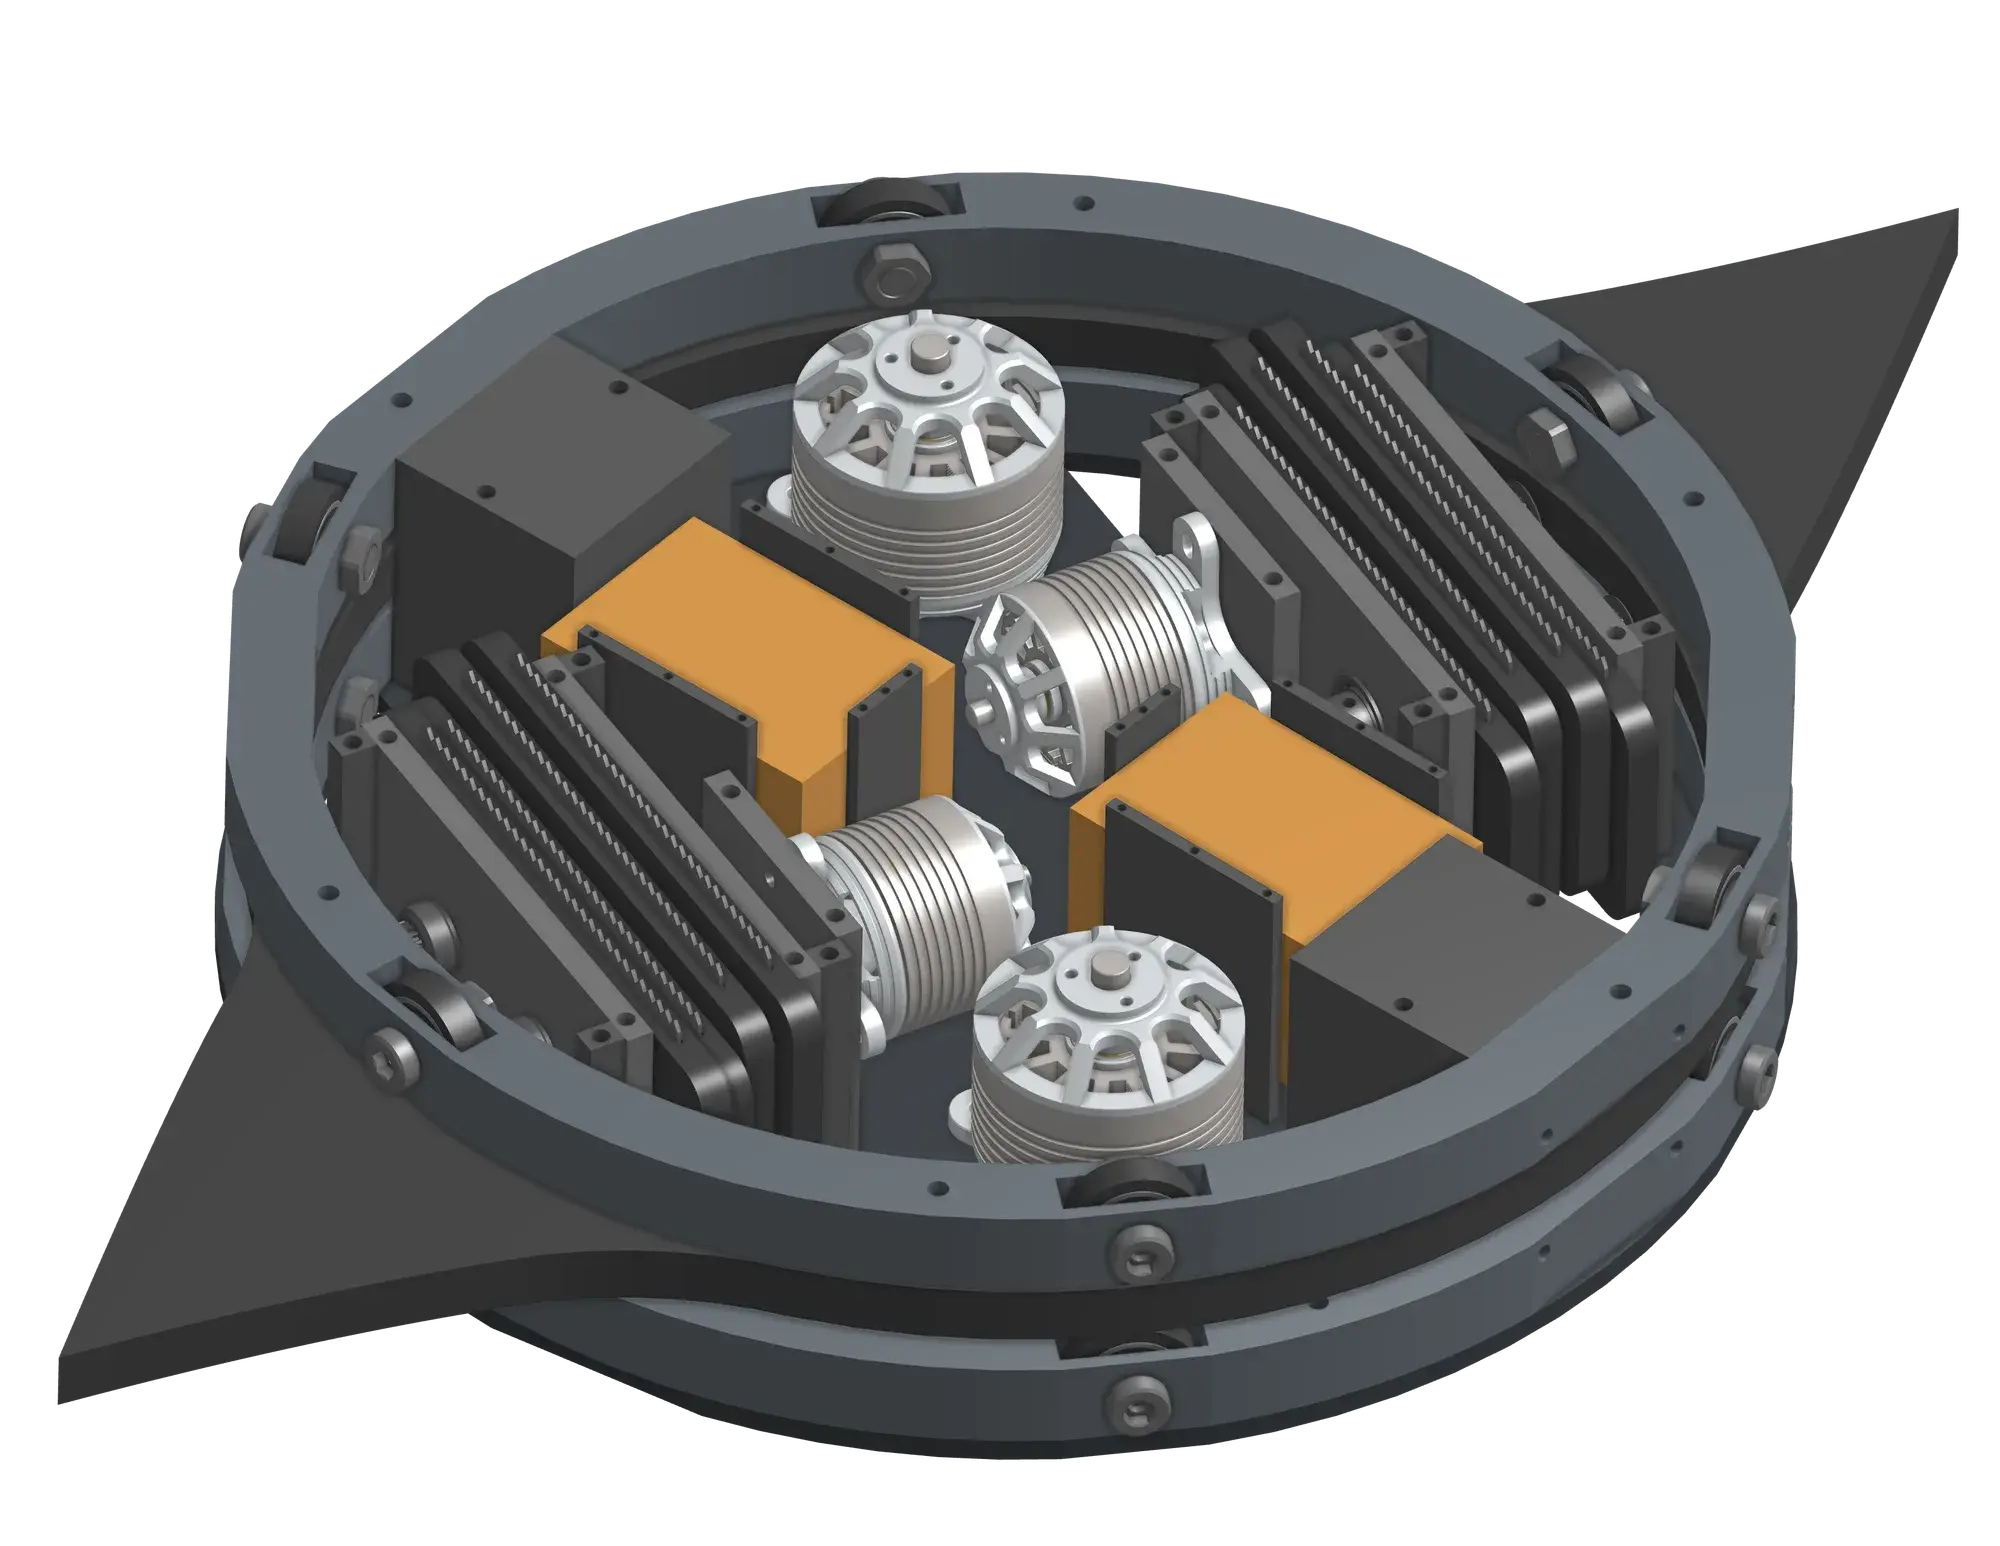
Ring-Spinner Weapon for an 18 lb Combat Robot
A 3 kJ spinning ring weapon designed by constrained optimization and checked with true FEA, which caught a stress flaw a simpler model hid.
 P·15
Machine Learning Complete
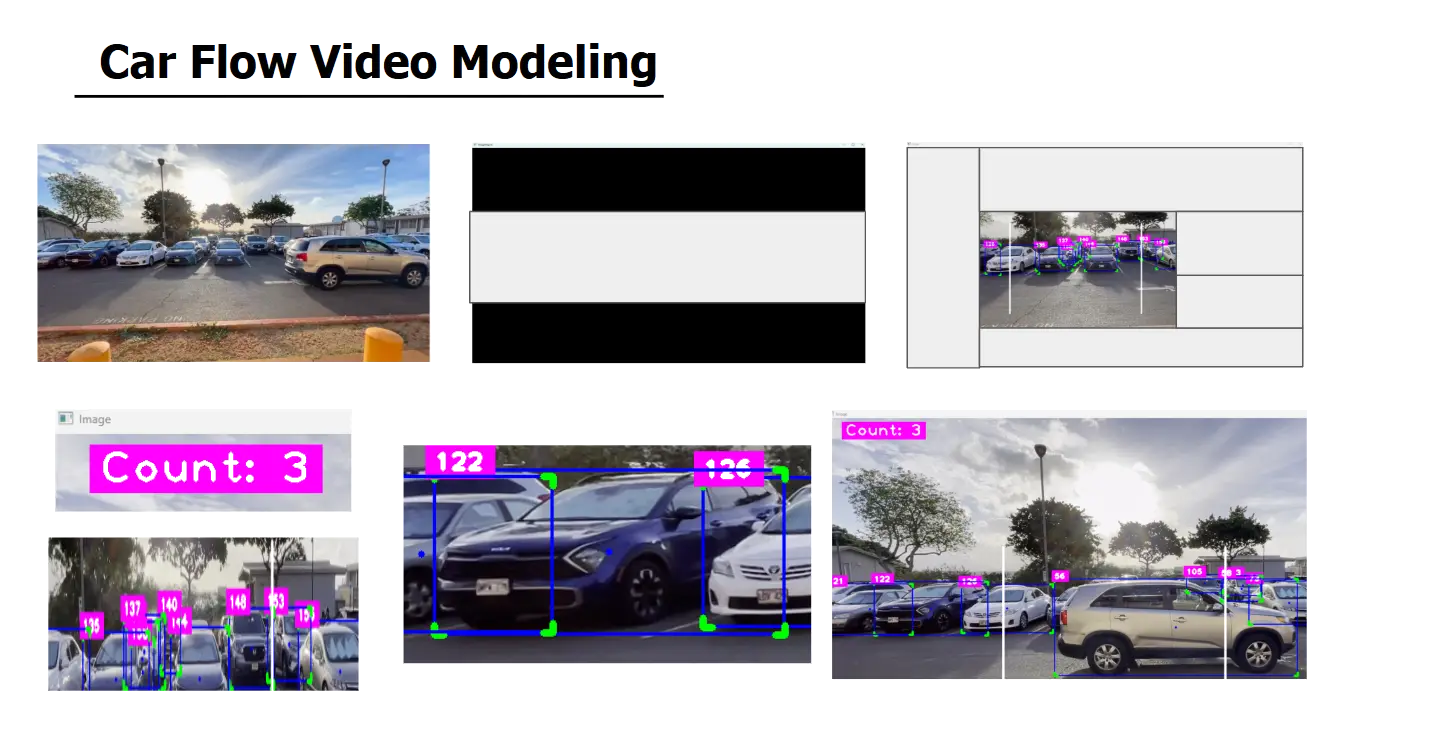
Traffic Flow Analysis with Computer Vision
A YOLOv8 pipeline that counts and tracks vehicles from stitched video in place of hand counts, plus a new traffic-efficiency equation.
 P·16
Electrical Complete
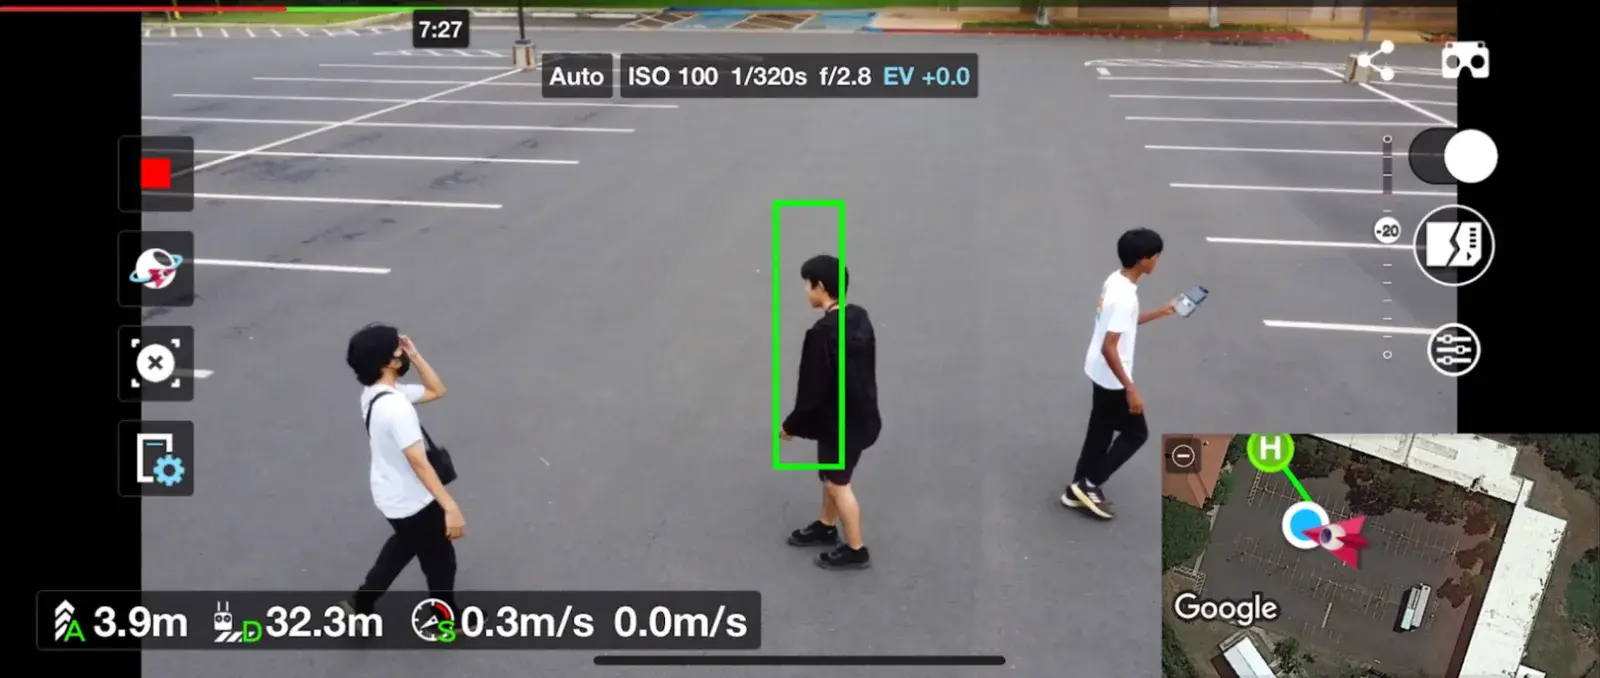
Autonomous Drone Search and Tracking for Campus Lockdowns
A drone system that maps a campus, sweeps it on an autonomous search route, and follows a person, flown in a restricted, school-approved test area.
 P·17
Machine Learning Complete
Walking Through a Photograph
One handheld 360° video turned into a real-time 3D Gaussian Splat in the browser, with camera poses solved to 0.97 px from 360° footage.
No projects in this category yet.